


导读:本文是机器人领域顶级会议 IROS 2021入选论文《基于无监督学习环境模型的机器人运动控制(DMotion: Robotic Visuomotor Control with Unsupervised Forward Model Learned from Videos)》的解读。该论文由北京大学前沿计算研究中心董豪课题组主导完成。
论文地址:****https://arxiv\.org/abs/2103\.04301
研究背景
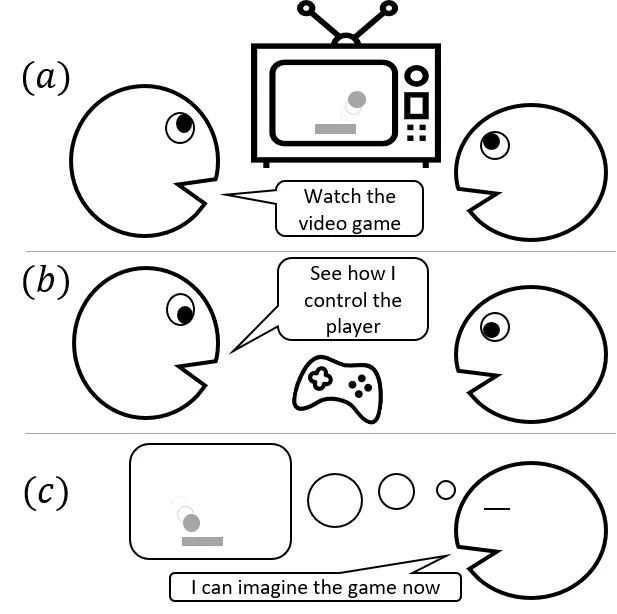
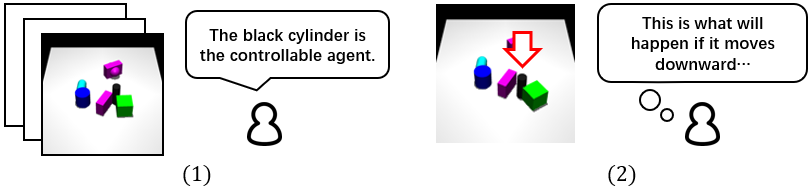
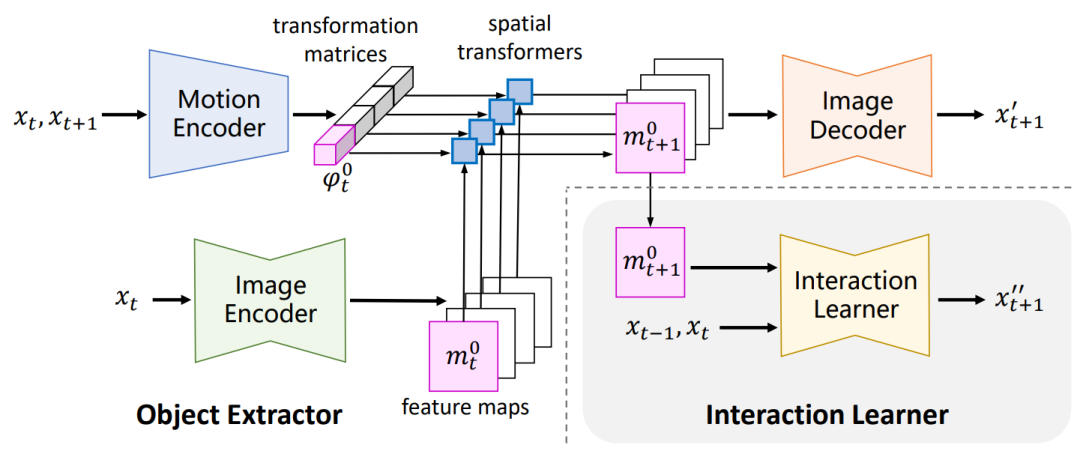
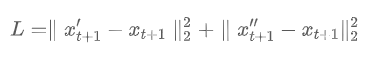
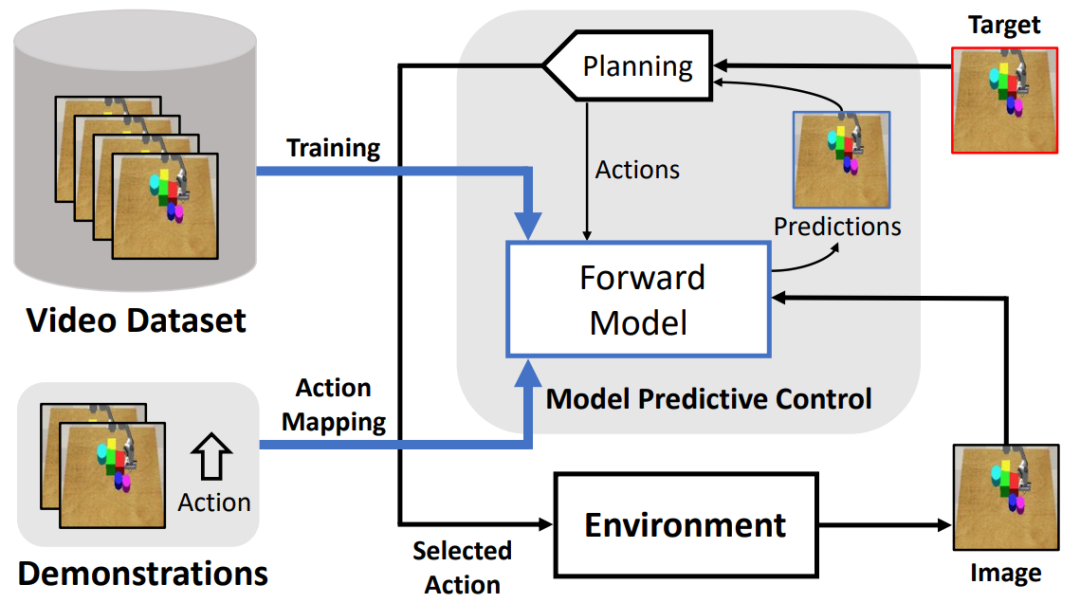
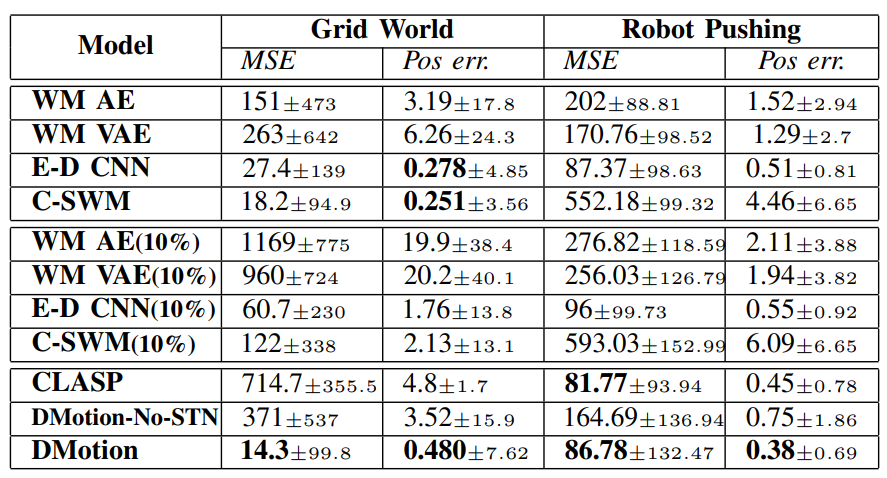
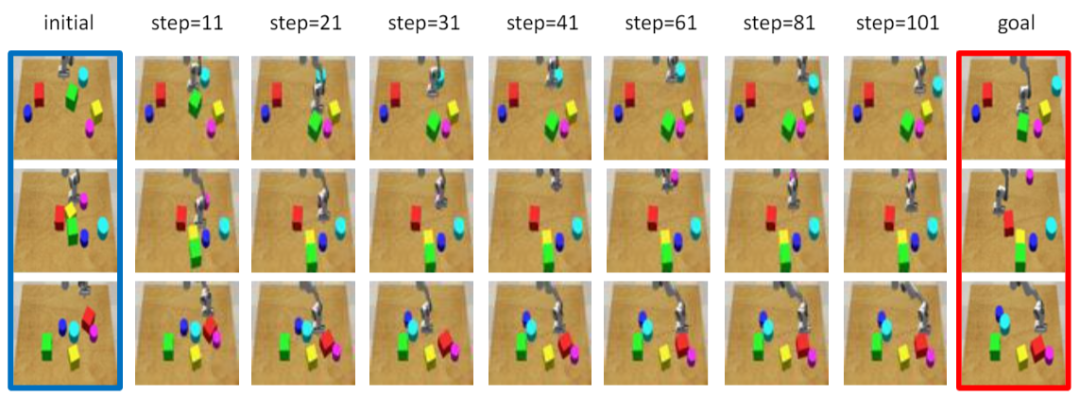
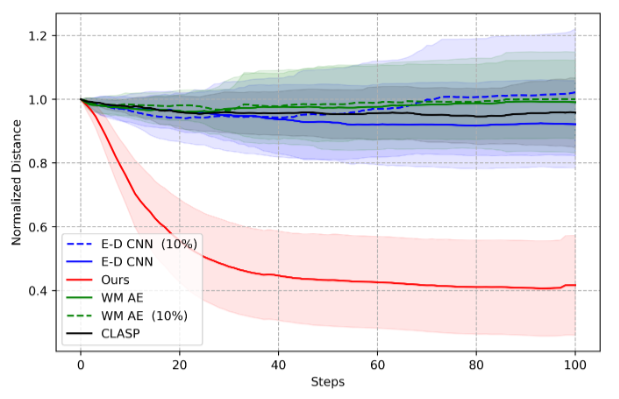
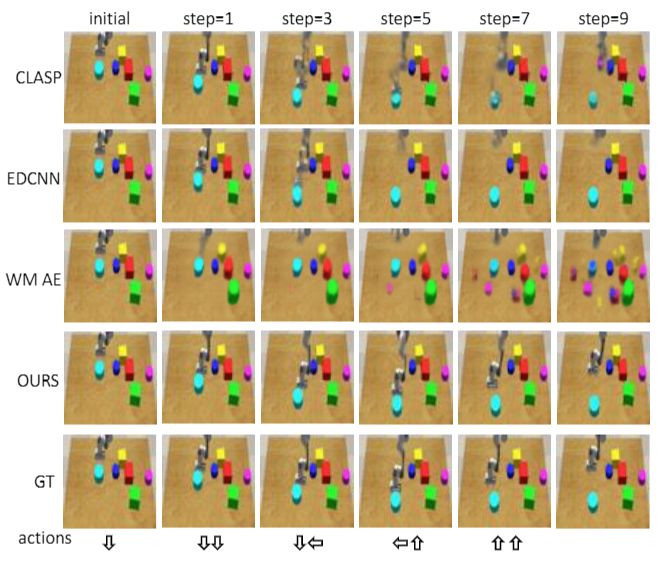
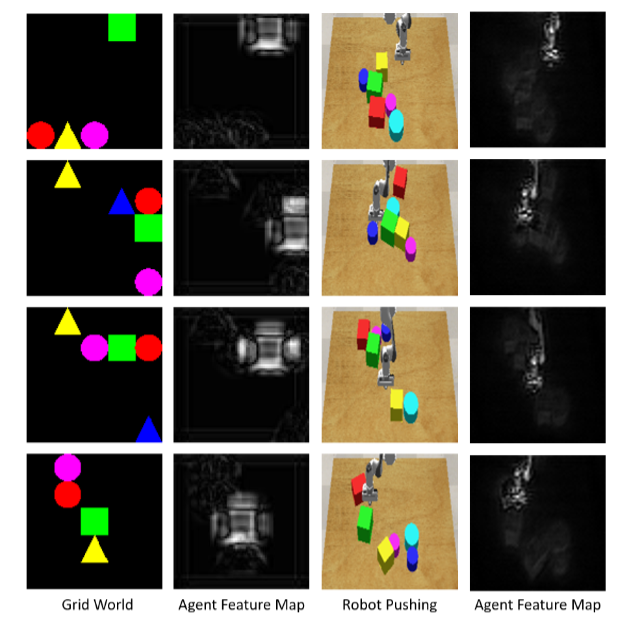
雷锋网雷锋网雷锋网
雷峰网特约稿件,未经授权禁止转载。详情见转载须知。
[
](https://vip.yanxishe.com/?from=leiphonearticle)
原文链接: https://www.leiphone.com/category/academic/bolmmUXzmEb2eyrQ.html
Loading...
TS
